Data · Tasks · Evaluation

Datasets & benchmarks

Find the data, choose a task and check its evaluation protocol. The catalogue brings together 17 dataset families and 23 evaluation tracks across MaCVi editions.

Filter by environment

17 dataset families

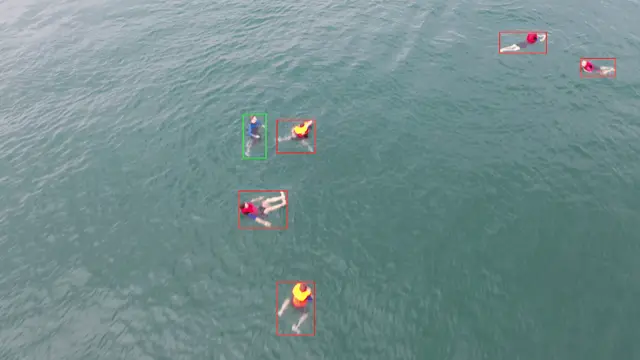
SeaDronesSee aerial scene with object annotations
Aerial

SeaDronesSee

Aerial search-and-rescue imagery, video sequences and flight metadata.

RGBFlight metadataSearch & rescue
Detection v1 · share unavailable
Code & documentation ↗Ask about v1 access ↗

The original detection v1 download share is unavailable. Ask the organisers for v1 access; detection v2 uses a different benchmark split.

5 evaluation tracks · metrics & formats

SeaDronesSee · detection v1

Find people, boats and other maritime objects in aerial views.

Metrics
AP / AR
Submit
COCO JSON

SeaDronesSee · detection v2

Detect small maritime objects across diverse flight heights and views.

Metrics
AP / AR
Submit
COCO JSON

SeaDronesSee · single-object tracking

Keep one target in view through a complete video sequence.

Metrics
Success / precision
Submit
ZIP of per-sequence TXT files
SeaDronesSee video sample

SeaDronesSee · multi-object tracking

Follow multiple maritime objects while preserving their identities.

Metrics
HOTA / MOTA / IDF1
Submit
ZIP of tracking TXT files

SeaDronesSee · tracking with re-identification

Recover object identities across longer and interrupted observations.

Metrics
HOTA / MOTA / IDF1
Submit
Track-specific JSON
MODS scene with water and obstacle annotations
Surface

MODS

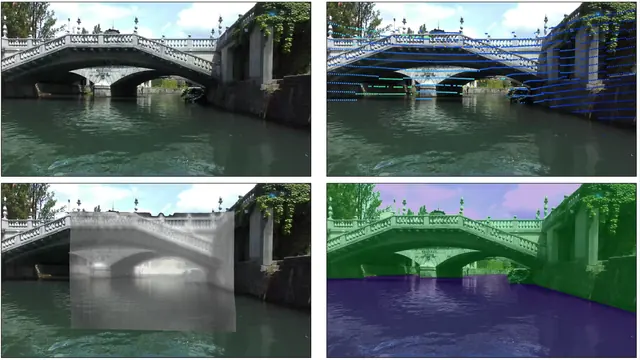
Boat-mounted scenes for water-edge understanding and obstacle detection.

RGBWater edgeObstacle avoidance
Evaluation toolkit ↗
2 evaluation tracks · metrics & formats

MODS · obstacle detection

Find navigational obstacles from an unmanned surface vessel.

Metrics
Sequence-averaged F score
Submit
Track-specific ZIP

MODS · obstacle segmentation

Separate navigable water, obstacles and sky.

Metrics
Water edge / F1 / danger zone
Submit
ZIP of segmentation masks
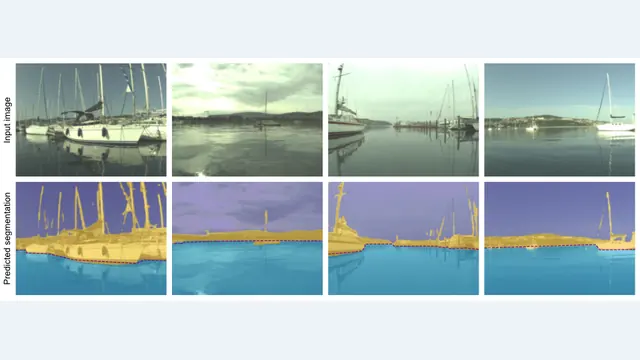
LaRS scene and panoptic annotations
Surface

LaRS

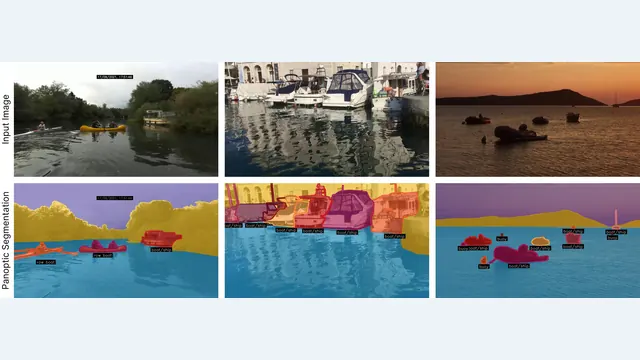
Diverse maritime scenes with semantic labels and individual obstacle instances.

RGBPixel labelsTemporal context
Project page ↗
4 evaluation tracks · metrics & formats

LaRS · semantic segmentation

Label water, sky and obstacles at pixel level.

Metrics
Q / water edge / F1 / mIoU
Submit
ZIP of semantic masks

LaRS · panoptic segmentation

Recognise scene regions and separate individual obstacles.

Metrics
PQ / SQ / RQ
Submit
ZIP of panoptic masks

LaRS · embedded segmentation

Balance segmentation quality with throughput on constrained hardware.

Metrics
Segmentation quality / FPS
Submit
ONNX model; validation step available

LaRS · obstacle detection

Detect obstacles in forward-facing boat-camera images.

Metrics
F1
Submit
Track-specific JSON
Aligned MULTIAQUA RGB, thermal, LiDAR and semantic examples
Surface

MULTIAQUA

Aligned RGB, thermal and LiDAR observations for perception from day to night.

RGBThermalLiDARDay & night
Challenge & protocol ↗
1 evaluation track · metrics & formats

MULTIAQUA · multimodal segmentation

Combine three sensor modalities to understand difficult low-light scenes.

Metrics
Daytime / nighttime mIoU
Submit
ZIP of segmentation predictions
BoaTrack boat-mounted video sample
Surface

BoaTrack

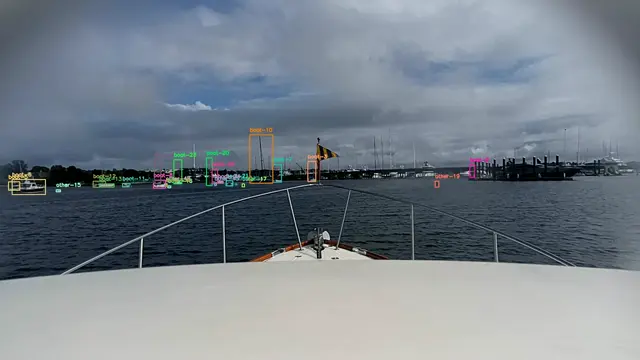
On-water video for tracking boats and other visible maritime objects.

RGBVideoObject identities
1 evaluation track · metrics & formats

BoaTrack · multi-object tracking

Track maritime objects from a moving boat.

Metrics
HOTA / MOTA / IDF1
Submit
ZIP of tracking TXT files
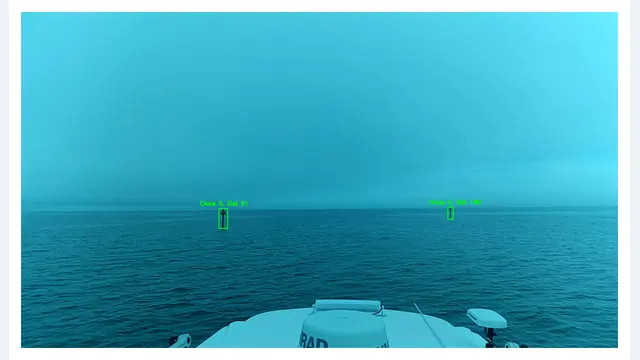
Buoy detection and distance-estimation sample
Surface

Object distance estimation

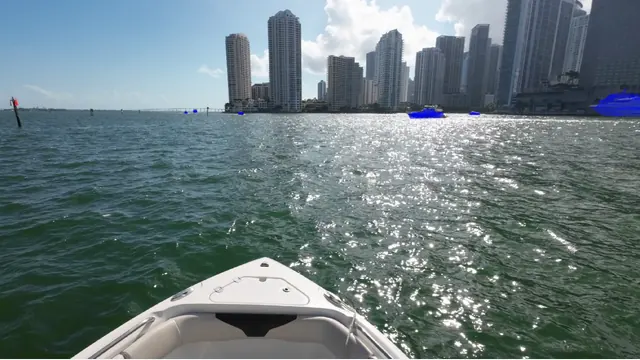
Monocular imagery with navigational-aid positions and distance targets.

RGBBuoysRange
1 evaluation track · metrics & formats

Monocular object distance estimation

Detect buoys and estimate how far they are from the camera.

Metrics
AP / absolute & relative range error
Submit
ONNX model
Maritime visual odometry dataset overview
Surface

Maritime visual odometry

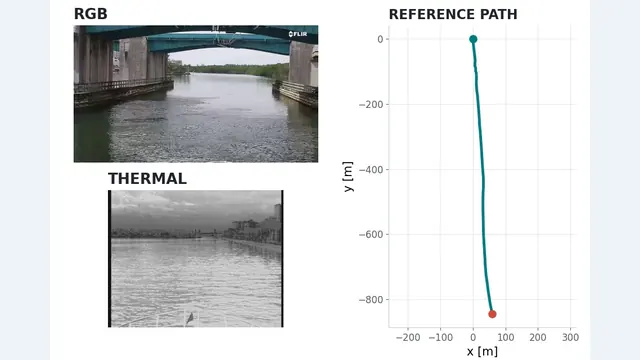
Boat-camera sequences, calibration and timestamps for estimating motion.

RGBCamera motionCalibration
1 evaluation track · metrics & formats

Maritime visual odometry

Recover a camera trajectory from boat-mounted video.

Metrics
Trajectory drift / temporal coverage
Submit
Challenge-specific JSON
Boat-camera motion preview
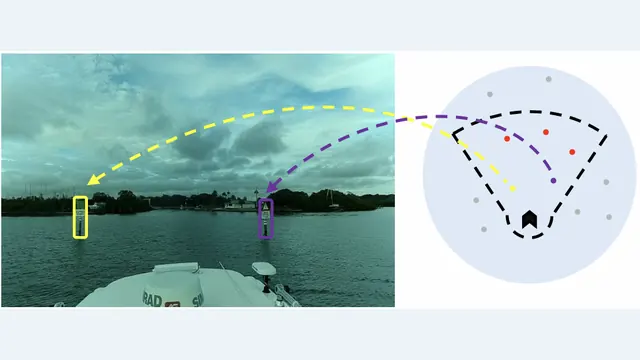
Buoys in camera imagery associated with chart markers
Surface

Vision-to-chart data association

Boat-camera imagery paired with chart markers for navigational aids.

RGBChartsAssociation
1 evaluation track · metrics & formats

Vision-to-chart data association

Match visible buoys to the corresponding markers on a nautical chart.

Metrics
Precision / recall / mIoU
Submit
JSON predictions; final ZIP as specified
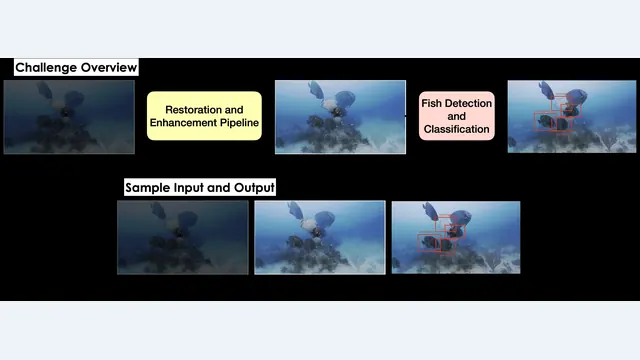
MarineVision Restoration paired degraded and restored underwater examples
Underwater

RSUIGM-Extended / MarineVision Restoration

Underwater imagery with degraded inputs and reference images for restoration.

RGBPaired imagesMarine species
1 evaluation track · metrics & formats

MarineVision restoration

Restore degraded underwater imagery while preserving useful visual detail.

Metrics
Detection / restoration quality
Submit
ZIP of restored predictions
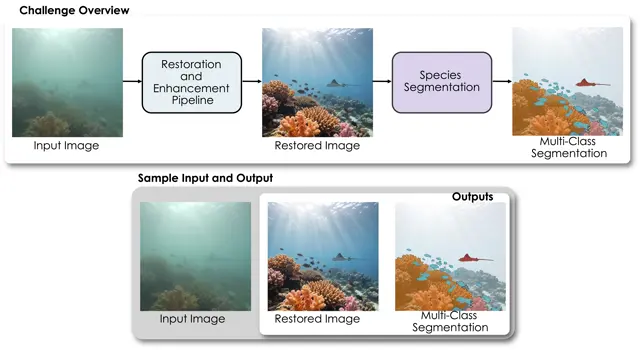
EURS underwater restoration and semantic segmentation examples
Underwater

EURS

Underwater restoration and semantic segmentation, including embedded evaluation.

RGBRestorationSemantic labelsEmbedded
2 evaluation tracks · metrics & formats

EURS · public development evaluation

Explore restoration and segmentation on the public development split.

Metrics
Restoration / segmentation composite
Submit
ZIP of predictions
Development-set leaderboard · unofficial

EURS · Jetson embedded evaluation

Evaluate the full restoration and segmentation model on Jetson hardware.

Metrics
Quality / latency / composite
Submit
ONNX model
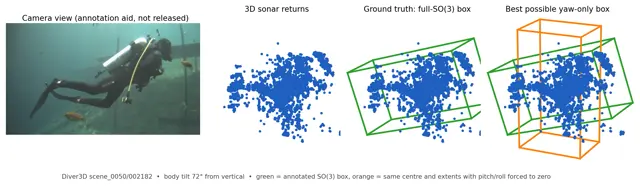
Diver3D sonar point clouds and diver annotations
Underwater

Diver3D

Sparse 3D imaging-sonar point clouds with oriented diver annotations.

3D sonarPoint cloudsDivers
1 evaluation track · metrics & formats

Diver3D · 3D sonar detection

Detect divers and estimate oriented 3D bounding boxes.

Metrics
SDS / 3D AP / localisation error
Submit
Challenge-specific JSON
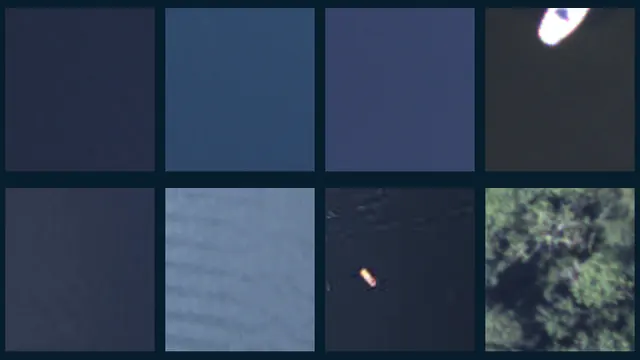
Eight real Boat-MNIST training patches
Aerial

Boat-MNIST

Small image patches for a simple watercraft-present classification task.

RGB patchesClassificationSmall models
1 evaluation track · metrics & formats

Boat-MNIST · image classification

Decide whether an image patch contains a watercraft on the water.

Metrics
Accuracy / parameter count
Submit
ONNX model
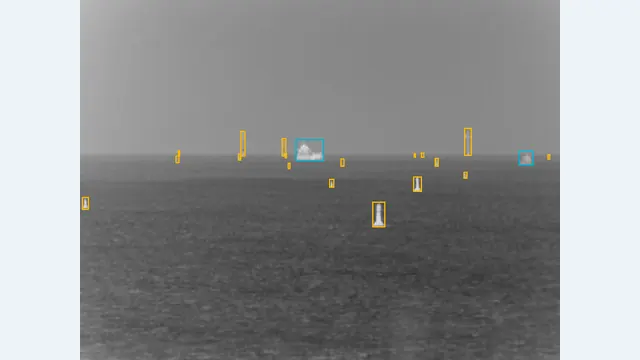
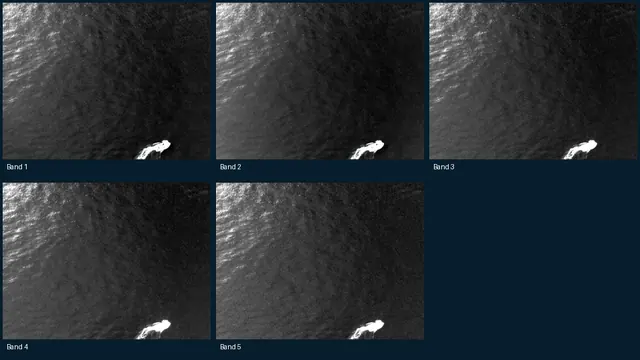
Contrast-normalized views of five bands from one SeaDronesSee multispectral training image
Aerial

SeaDronesSee multispectral

Multi-band UAV imagery and object annotations for maritime perception.

MultispectralUAVDataset only

Five bands shown with independent contrast normalization. No hosted leaderboard.

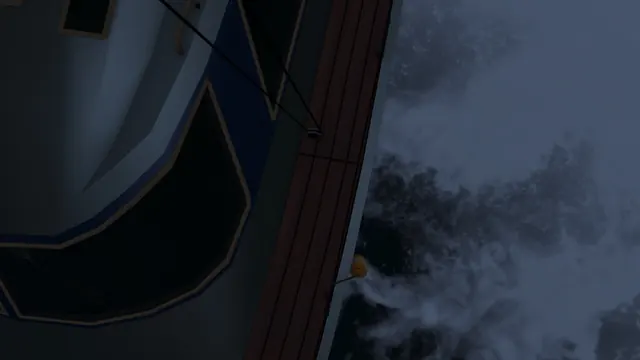
A real sample from the published synthetic SeaDronesSee training archive
Aerial

Synthetic SeaDronesSee

Rendered maritime UAV scenes for studying synthetic-to-real transfer.

Synthetic RGBTraining dataDataset only

Night-time synthetic training example. No hosted leaderboard.

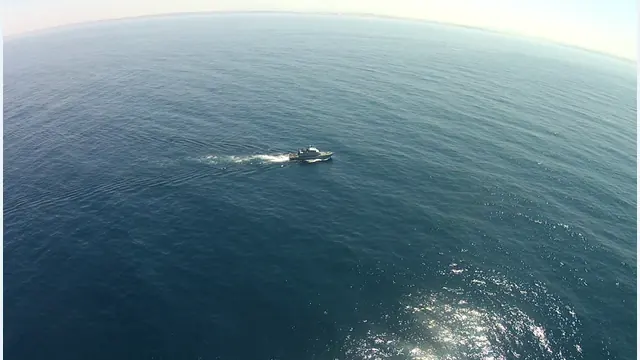
Seagull visible-spectrum maritime sample from VisLab
Aerial

Seagull

Fixed-wing UAV sequences spanning visible, infrared and near-infrared cameras.

Visible / IR / NIRVideoDataset only
VisLab project ↗

Sample: VisLab / Seagull. Dataset access is by request; no MaCVi leaderboard.

From data to a benchmark result

  1. Get the data. Follow the dataset links and its access terms. Some resources require an access request.
  2. Check the protocol. Use the correct split, label IDs, calibration and preprocessing. Validate locally with the track's starter kit where available.
  3. Submit to the right track. A MaCVi account is needed for hosted submissions. Check the upload page and challenge rules for current limits and entry periods.

OpenReview profiles are used for workshop-paper and summary-paper authorship; they are separate from MaCVi dataset and benchmark accounts. Dataset access does not imply an open competition or automatic paper inclusion.

Object detection: COCO prediction JSON

SeaDronesSee detection v1/v2 and the thermal detection track use COCO-style detection results: one object per array entry. Match the image and category IDs to the selected dataset.

[
  {"image_id": 6503, "category_id": 4, "score": 0.68,
   "bbox": [426.15, 563.64, 43.33, 18.98]}
]

Boxes use pixel coordinates [x, y, width, height]. Check the task's categories and sample file; this example is not a submission for every detection benchmark.

SeaDronesSee single-object tracking: per-sequence text files

The test set has 80 clips. Put 1.txt through 80.txt at the root of a ZIP archive. Each file has one row per frame: x,y,width,height in pixels. Follow the sequence/frame mapping supplied with the dataset.

Single-object tracking documentation →

Multi-object tracking: identities across frames

For standard SeaDronesSee MOT, submit a ZIP with one [video_id].txt file per sequence at its root. Each row is frame_id,object_id,x,y,width,height. Frame IDs follow the dataset annotations; object IDs are assigned by your tracker.

BoaTrack and re-identification have their own protocol. In particular, the re-identification track accepts JSON; do not reuse another track's ZIP format without checking its instructions.

SeaDronesSee tracking protocol → · BoaTrack protocol →

LaRS semantic and panoptic segmentation: different mask encodings

Use one PNG prediction per evaluation image, with matching filenames, at the root of a ZIP archive.

Semantic: water (41,167,224), obstacles (247,195,37), sky (90,75,164).

Panoptic: red encodes the class ID; green and blue encode instance_id = G × 256 + B. Use the published class IDs: static obstacles 1, water 3, sky 5, boat/ship 11, row boat 12, paddle board 13, buoy 14, swimmer 15, animal 16, float 17, other 19; 0 is void.

Semantic protocol → · Panoptic protocol →

ONNX models and specialist tracks

Boat-MNIST, BoaTetection, distance estimation and the embedded tracks evaluate uploaded models. Use their required input/output shapes, normalisation, export settings and validation steps.

MULTIAQUA, restoration, vision-to-chart, visual odometry and Diver3D each define a separate prediction or model contract. Open the dataset's “metrics & formats” above, then follow its protocol and starter kit.

Need help with data access or a submission? Check the FAQ or ask in the appropriate Discord challenge channel. Please cite the relevant dataset or challenge report and follow each dataset's licence.